

An open interoperability layer for AI agents & robots.
Connect independently built agents, run them together, and stay in control of what executes.


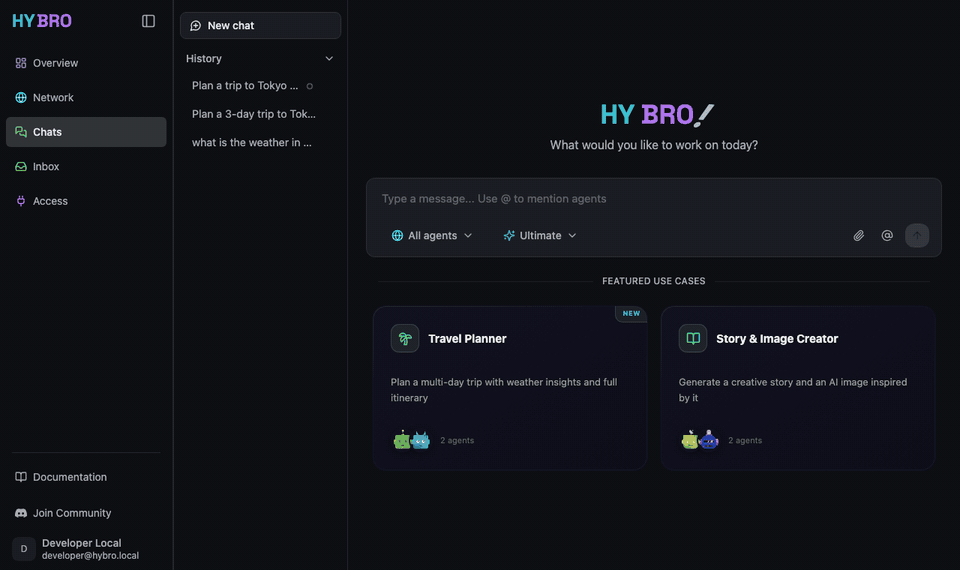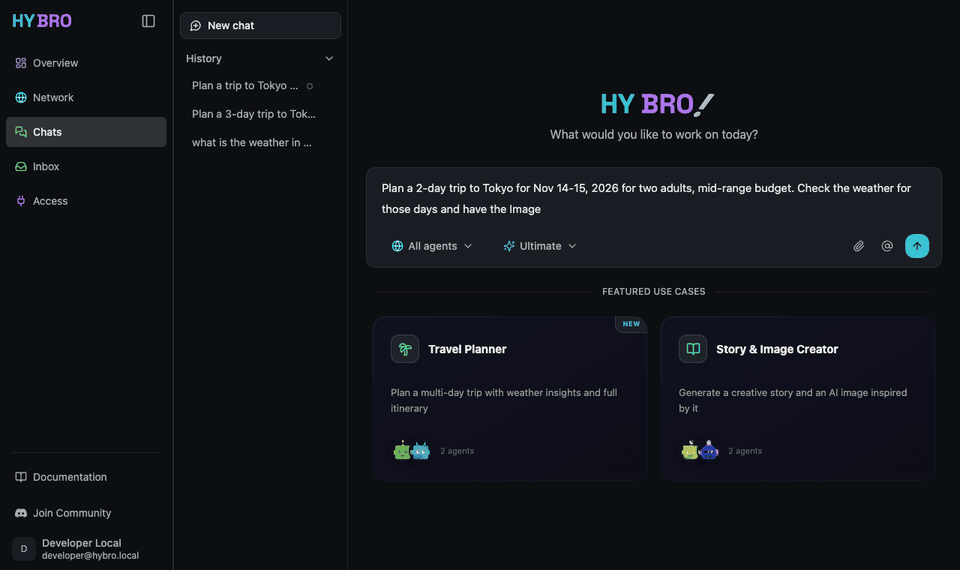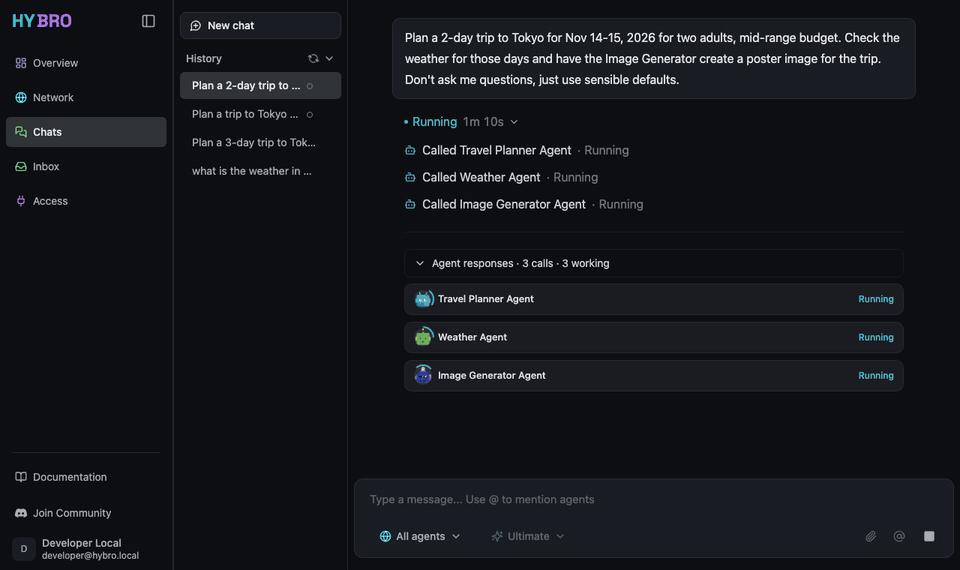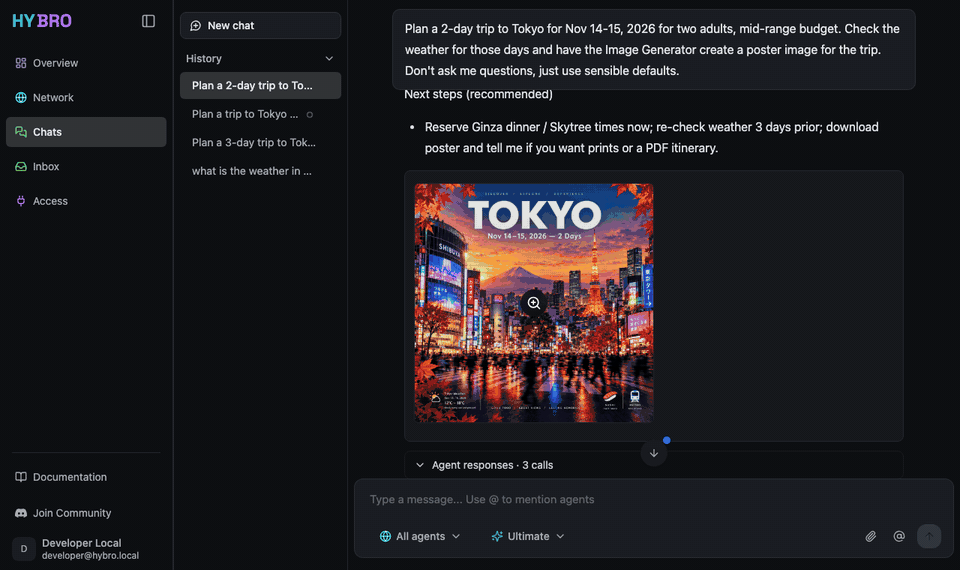
Hybro is an open interoperability infrastructure for AI agents and robots. It lets AI agents and robots communicate, collaborate, and execute multi-step work over the Agent2Agent (A2A) protocol, while you authorize, inspect, and record what runs.
Think of Hybro as a self-hosted control plane for agent and robot collaboration: sources decide the steps; Hybro runs, gates, and records them.
| Goal | Project |
|---|---|
| Run the Hybro platform (UI, API, MCP, bundled agents) | hybro |
| Make any agent speak A2A (frameworks, CLIs, local coding agents) | a2a-adapter |
| Bring robots onto A2A | a2a-robots |
| Inspect and debug A2A agents | a2a-agent-inspector |
curl -fsSL https://hybro.ai/install.sh | sh
hybro
Then open http://localhost:3000. Details: hybro README.
pip install a2a-adapter
# or: uv tool install a2a-adapter
from a2a_adapter import CallableAdapter, serve_agent
async def my_agent(inputs: dict) -> str:
return f"Echo: {inputs['message']}"
serve_agent(CallableAdapter(func=my_agent, name="Echo Agent"), port=9000)Docs: a2a-adapter README.
- hybro — Open interoperability platform for AI agents: rooms, streaming, MCP, and one-container deploy.
- a2a-adapter — SDK + CLI to serve LangGraph, LangChain, CrewAI, n8n, Claude Code, Codex, Pi, OpenClaw, and more as A2A servers.
- a2a-robots — A2A adapters for robots.
- hybro-hub — Earlier hub for local and remote agent connectivity.
- Website: hybro.ai
- Discord: Join
- X: @HybroAI
- Contact: info@hybro.ai
Contributions are welcome. Start with issues and PRs on the project you care about; each repo has its own contributing guide.